Shaohui Liu

Contact: "b1ueber2y at gmail dot com"         [Curriculum Vitae]
I joined in in Fall 2026, after completing my PhD from at advised by Prof. . My research focuses on geometric visual perception for real-world spatial understanding, grounded in multi-view geometry, robust estimation, and optimization. These methods are, in some cases, further enhanced by machine learning and foundation models. My recent research has centered on 3D computer vision and state estimation in both online and offline setup.

I have also had the oppportunity to gain practical experience through industrial internships at , , , and .
   Selected Projects   [Full list]


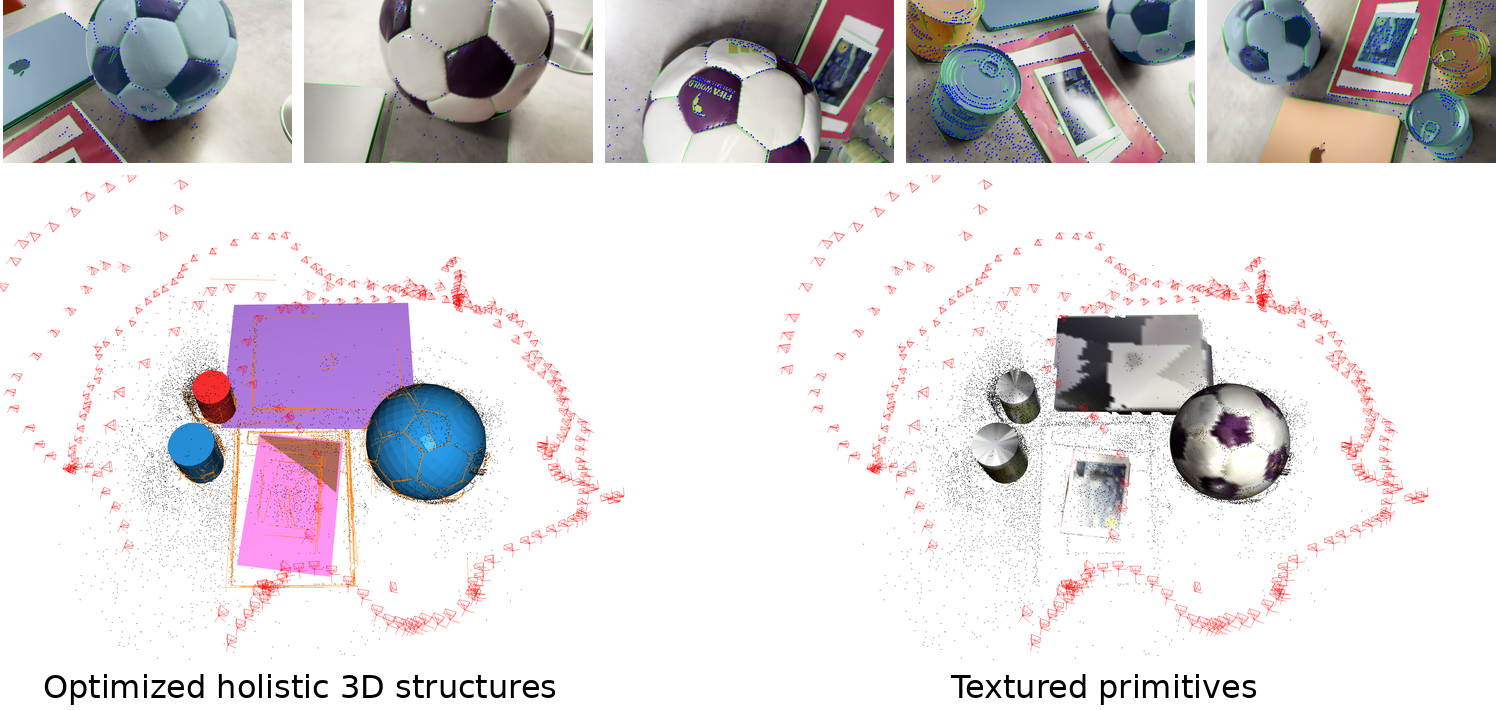
Stable and Scalable Bundle Adjustment of Holistic 3D Structures

Shaohui Liu, , , , ,

ECCV, 2026.         Released as part of LIMAP 2.0.


A unified bundle adjustment framework enables joint optimization of diverse 3D geometric structures and their relations while retaining the efficiency of classical point-based formulations.


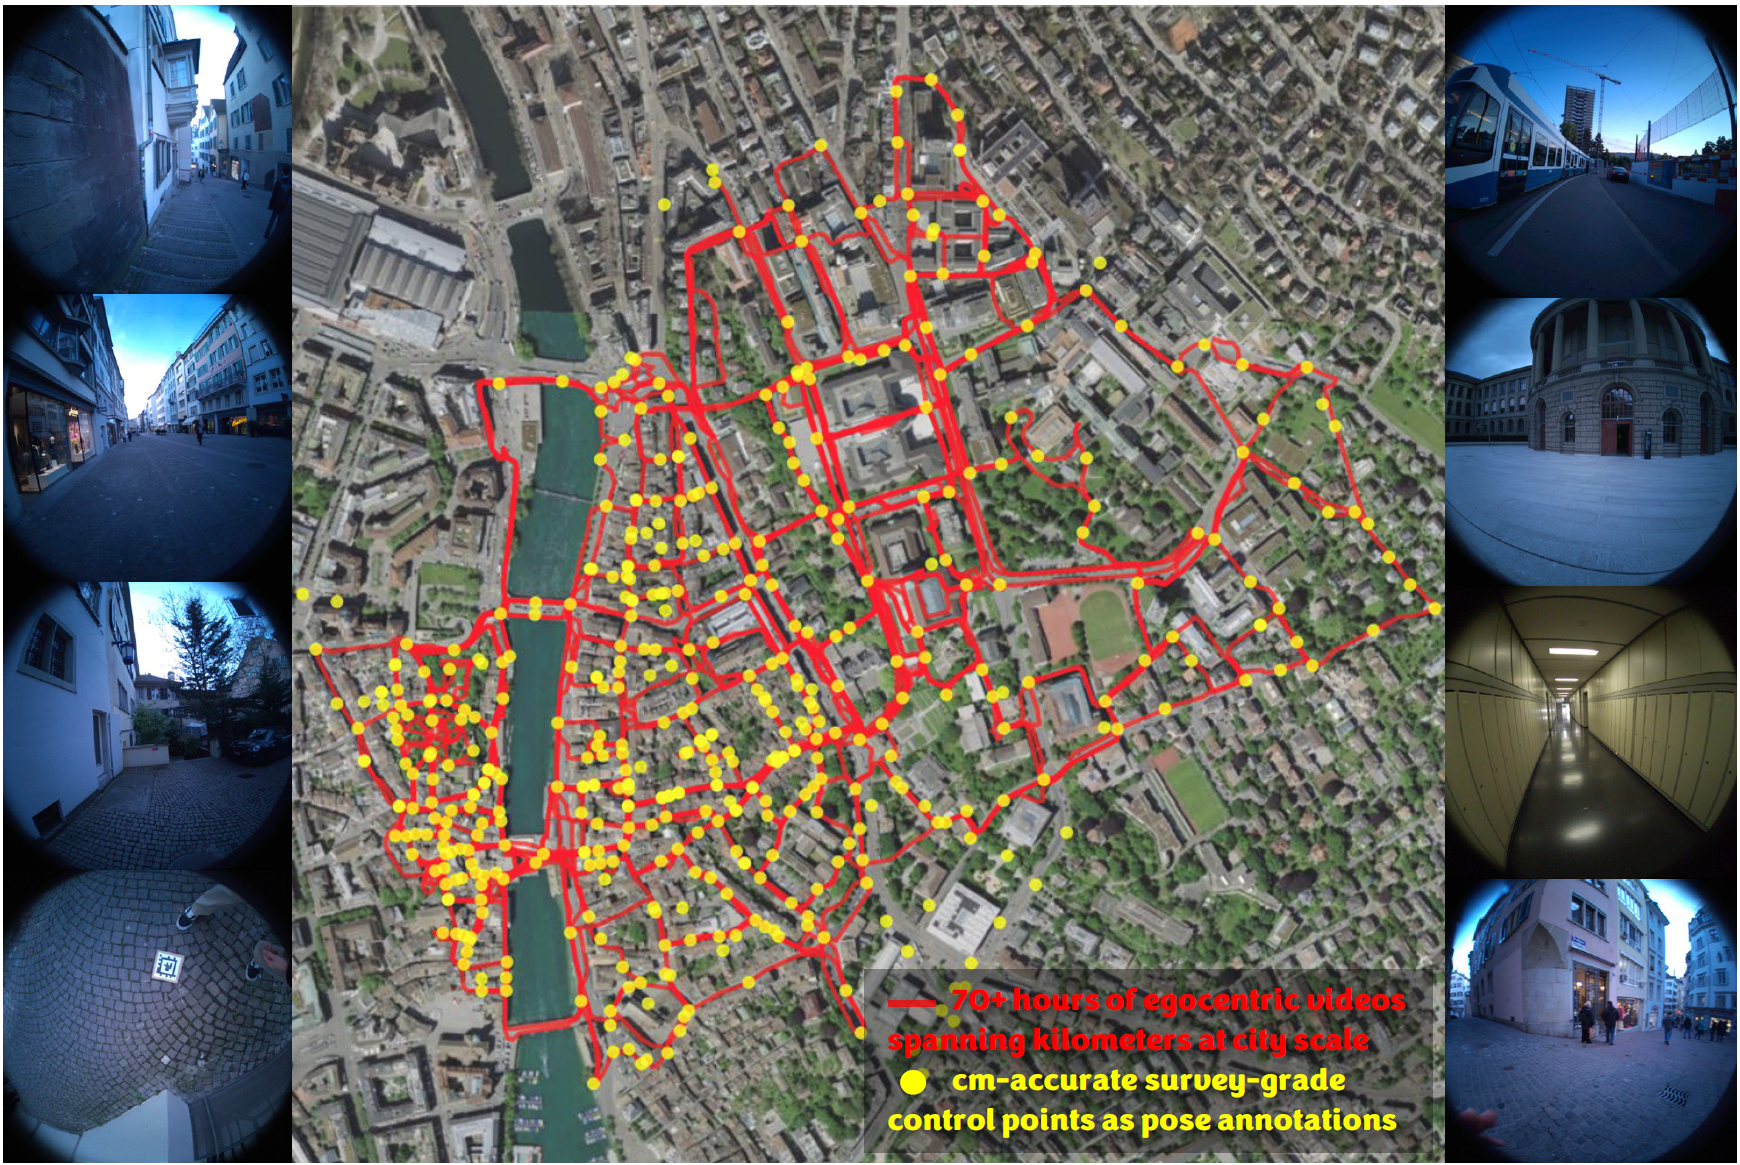
Benchmarking Egocentric Visual-Inertial SLAM at City Scale

*, Shaohui Liu*, *, , , , , ,

ICCV, 2025.         Selected as a highlight paper.


A city-scale dataset enables benchmarking of visual-inertial SLAM systems on egocentric videos spanning kilometers, with centimeter-accurate survey-grade control points as pose annotations.

Leaderboard: https://www.lamaria.ethz.ch/leaderboard


Relative Pose Estimation through Affine Corrections of Monocular Depth Priors

, Shaohui Liu, , ,

CVPR, 2025.         Selected as a highlight paper.


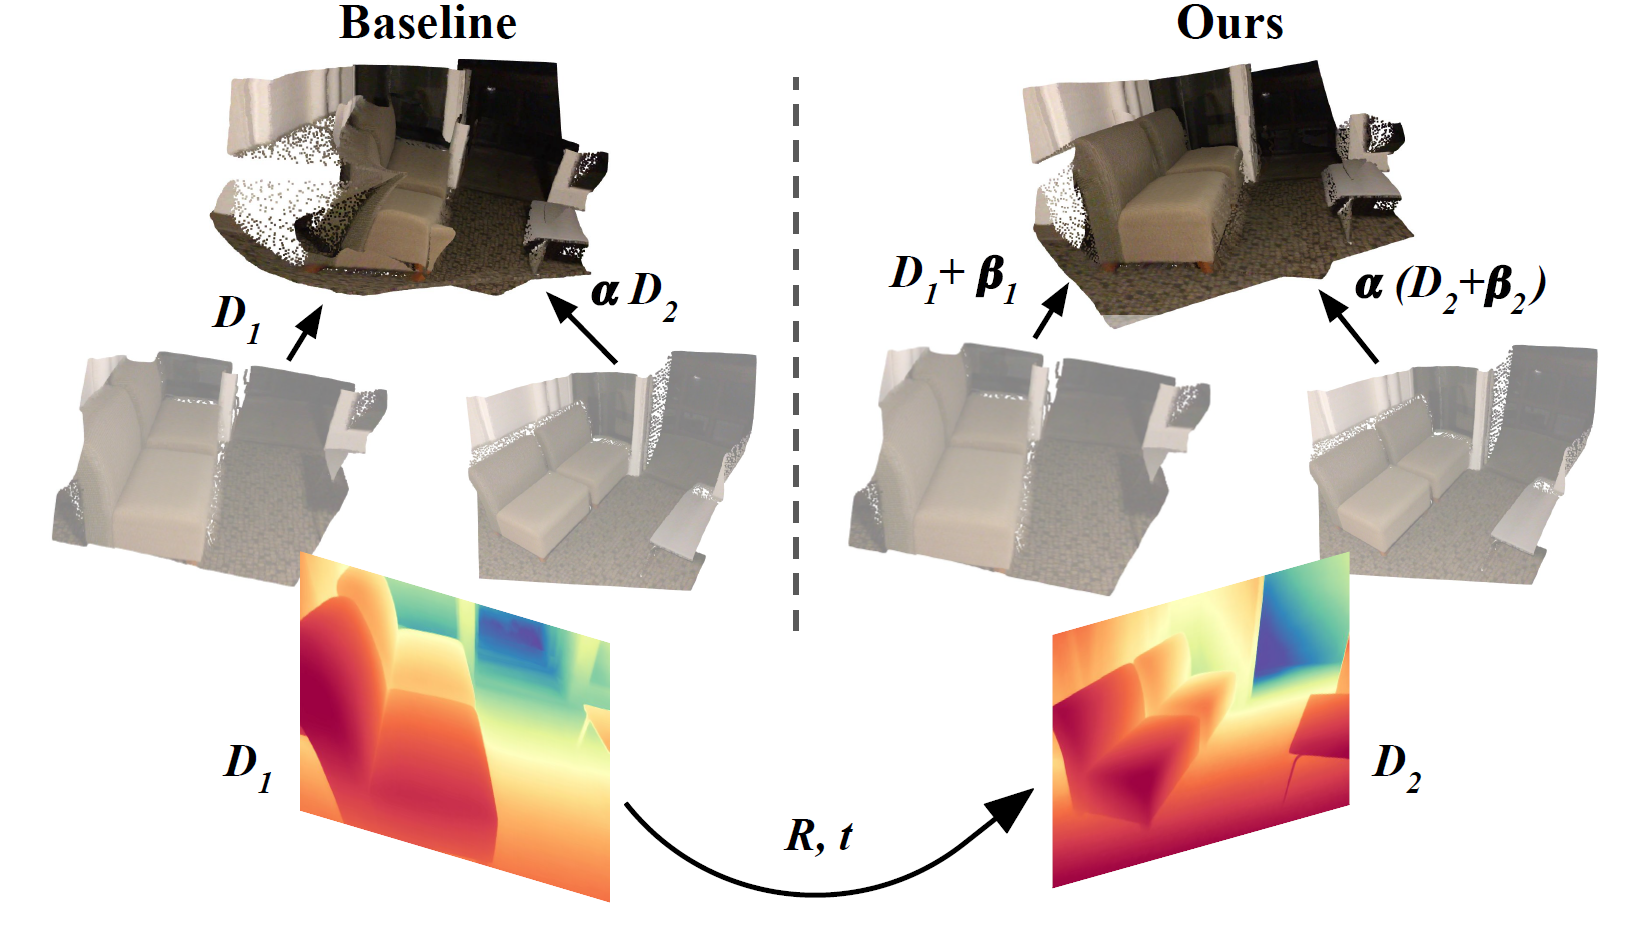
A group of new relative pose solvers benefit from both keypoint matching from classical geometry pipeline and monocular depth predictions from foundation models.


Reloc3r: Large-Scale Training of Relative Camera Pose Regression

*, *, Shaohui Liu, , , ,

CVPR, 2025.         From external collaboration.


Scaling up training yields a reasonably accurate relative pose regressor that runs 20x faster than existing estimators based on image matching and RANSAC.


Robust Incremental Structure-from-Motion with Hybrid Features

Shaohui Liu*, *, *, , , ,

ECCV, 2024.        


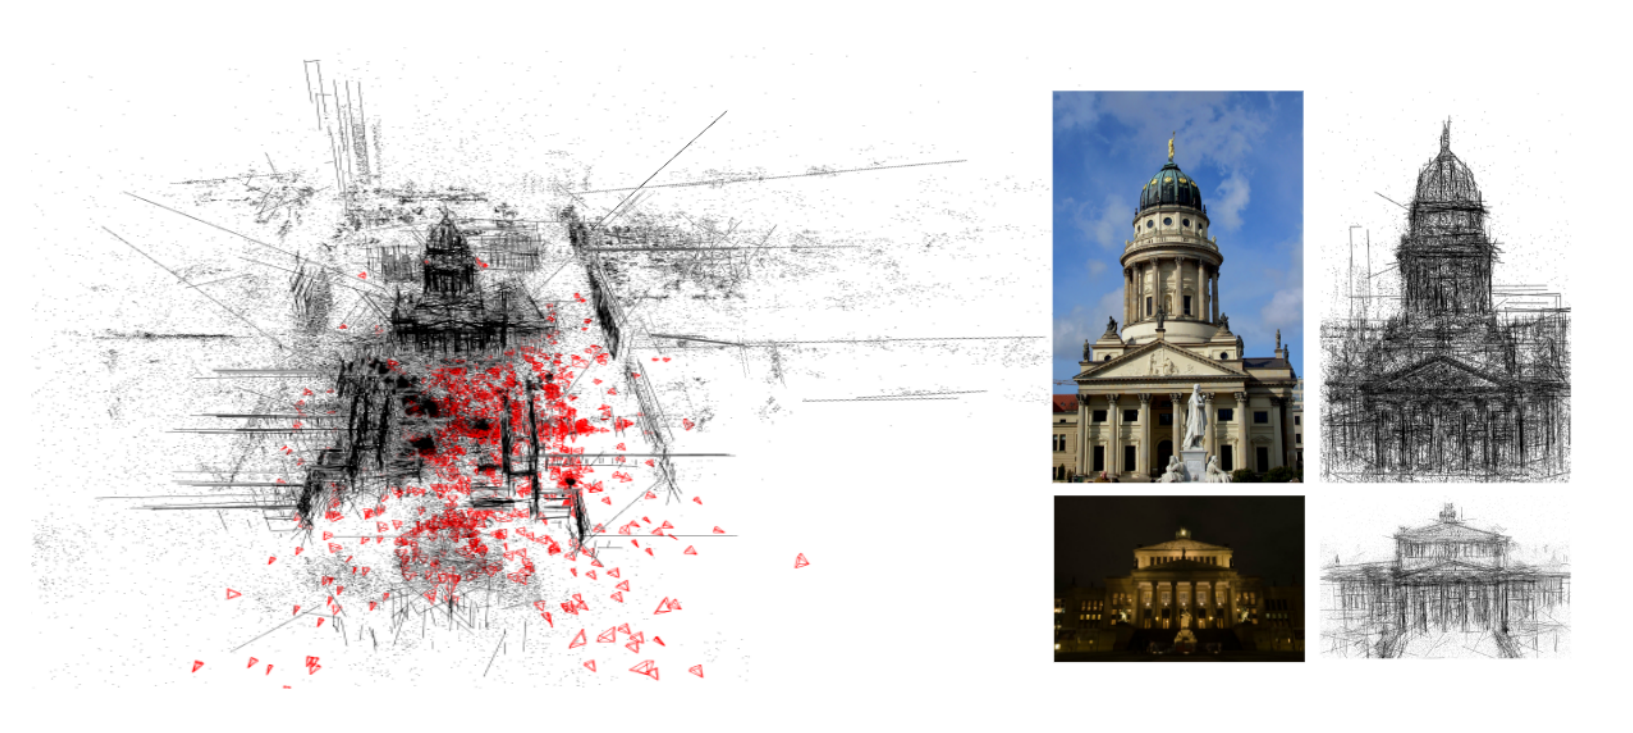
Incremental SfM of points, lines, and vanshing points, with analytic covariance propagation.


limap: 3D Line Mapping Revisited

Shaohui Liu, , , ,

CVPR, 2023.         Selected as a highlight paper.


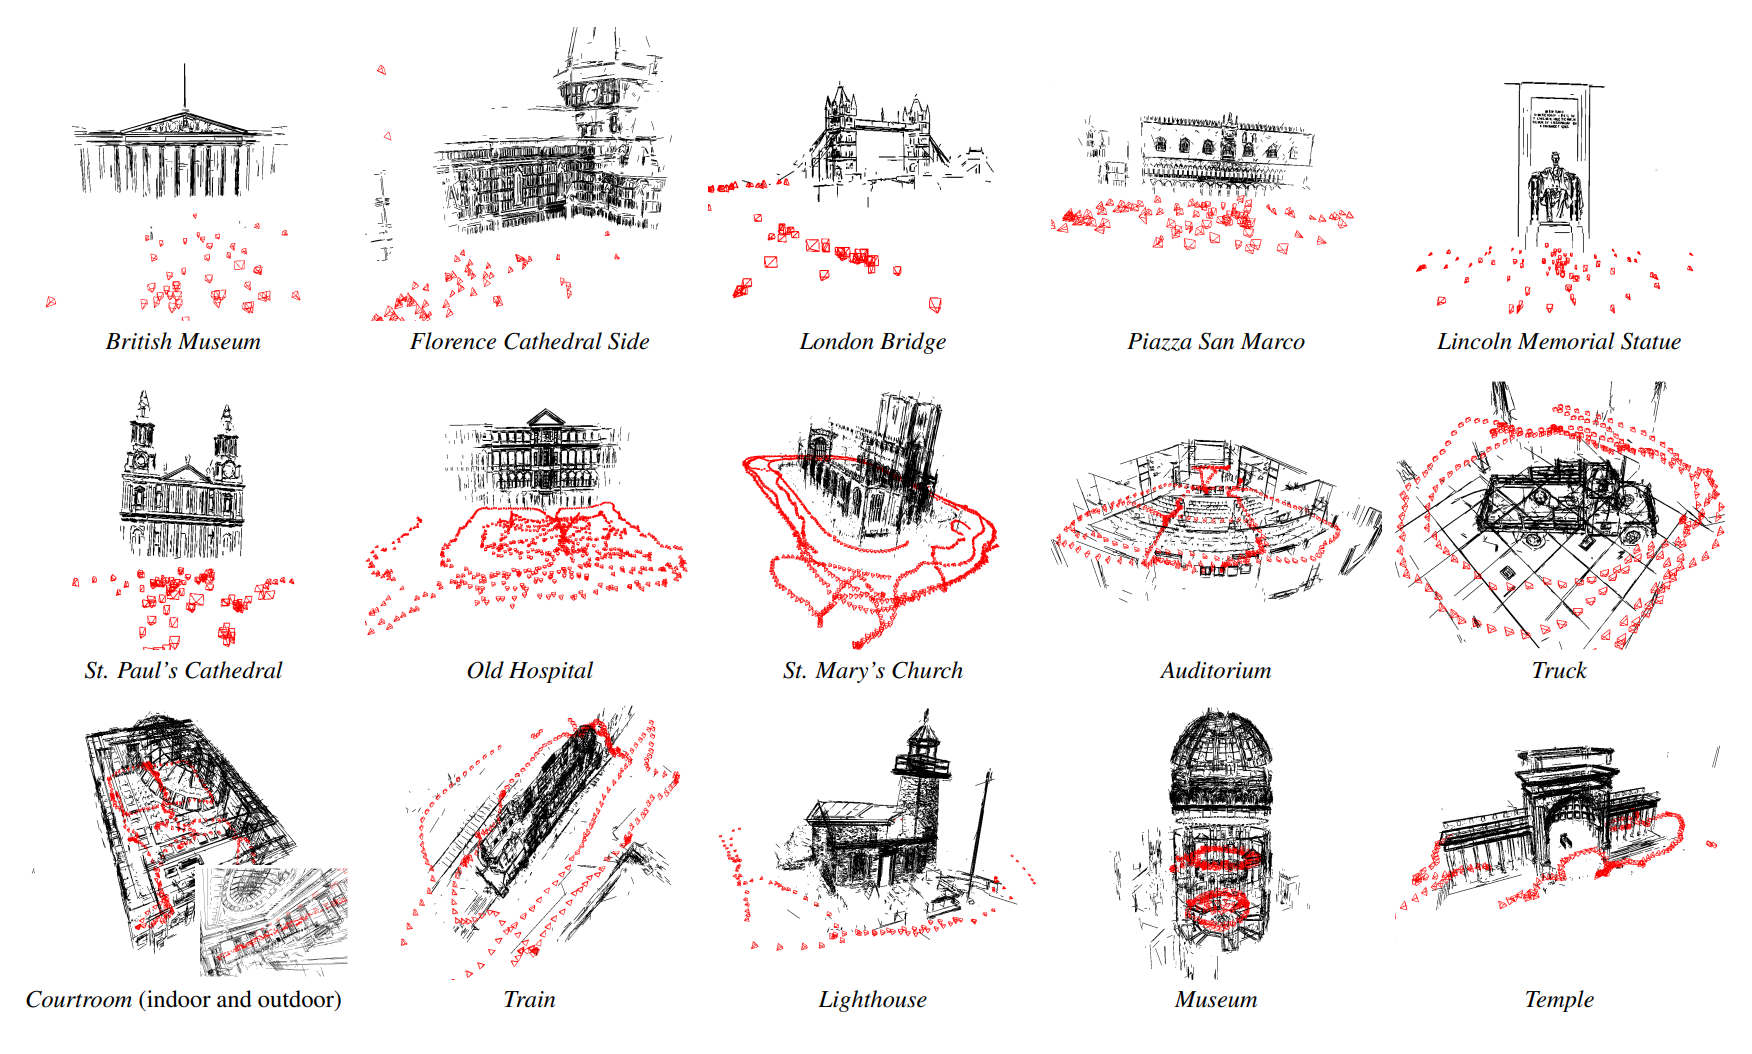
An open-sourced system that robustly and efficiently constructs 3D line maps from multi-view imagery benefits multiple downstream applications such as visual localization and hybrid bundle adjustment, while also being flexible to adaptation of different 2D line detectors and matchers.


ParticleSfM: Exploiting Dense Point Trajectories for Localizing Moving Cameras

, Shaohui Liu, , ,

ECCV, 2022.         Part of my intern project at .


Connecting, optimizing dense point trajectories from pairwise optical flows and segmenting them into labeled point tracks benefit an effective global structure-from-motion system for dynamic in-the-wild videos (image sequences) that exhibit complex foreground motions.


NerfingMVS: Guided Optimization of NeRF for Indoor Multi-view Stereo

, Shaohui Liu, , , ,

ICCV, 2021 / T-PAMI, 2023.         Accepted as an Oral.


Integrating conventional SfM + MVS reconstruction and learning-based depth priors largely improves the learned geometry of neural radiance fields (NeRF) in general indoor scenes, leading to significantly better multi-view depth estimation and novel view synthesis.


DIST: Rendering with Differentiable Sphere Tracing

Shaohui Liu, , , , ,

CVPR, 2020.         Most work was done at .


A new differentiable sphere tracing algorithm enables systems to efficiently render various 2D observations from deep implicit signed distance functions and effectively perform robust inverse geometric optimization over real-world images with great generalization capability.


Towards Better Generalization: Joint Depth-Pose Learning without PoseNet

, Shaohui Liu, ,

CVPR, 2020.


Instead of relying on a PoseNet-like architecture, explicitly solving relative pose from optical flow correspondence improves the performance and generalization of self-supervised joint depth-pose learning methods on multiple challenging scenarios.


RepPoints: Point Set Representation for Object Detection

*, Shaohui Liu*, , ,

ICCV, 2019.         Intern project at .


Using a set of representative points to connect stages for simultaneous semantically aligned feature extraction and flexible geometric 2D representation produces a brand new effective object recognition framework without the need of anchors and bounding boxes.


Project August: Efficient Face Tracking at More than 1k FPS on CPU

Major project developer at in 2017.


By caching, reusing and sharing intermediate features of a lightweight regression-based tracking model across frames we achieved extremely efficient face tracking and deployed the system onto real-world market products, as a preprocessing step for subsequent face analysis.